
ROS 2 Hardware Integration & Robotic Arm Bring-Up
Built a complete ROS 2-to-hardware control path for a physical robotic arm, integrating higher-level robot software with embedded firmware and physical actuation.
- ROS 2
- C++
- ros2_control
- MCU Firmware
- MoveIt 2
 Physical demo video coming soon
01
What it does
Built a complete ROS 2-to-hardware control path for a physical robotic arm, integrating higher-level robot software with embedded firmware and physical actuation.
The system connects ROS 2 trajectory commands through a C++ hardware layer, serial protocol and MCU firmware to bounded servo control, while exposing robot state, TF, diagnostics and safety behaviour back into the ROS 2 environment.
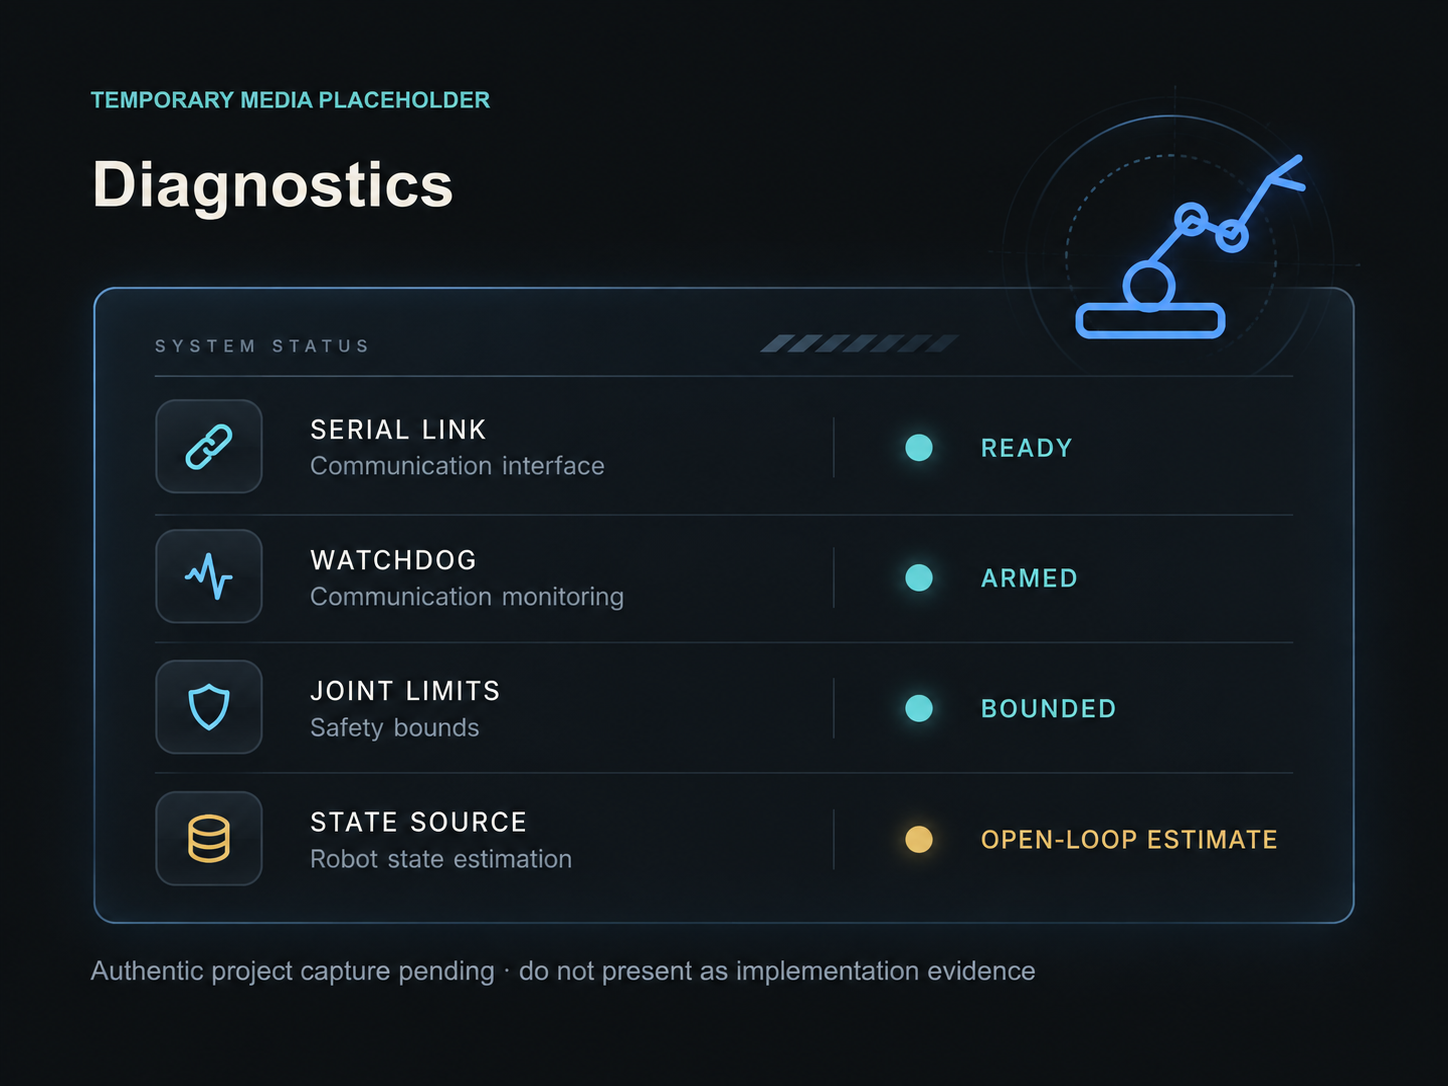
The integration includes bounded joint commands, malformed-command rejection, communication timeouts, watchdog behaviour, diagnostics, calibration management and defined behaviour on communication loss.
Open-loop state
The arm does not provide encoder-based joint-position feedback. ROS joint state therefore represents the last accepted commanded estimate rather than verified physical proprioception.
02
Demonstrations
 Capture pending
 Capture pending
 Capture pending
 Capture pending
03
System overview
Control path
- ROS 2
- C++ Hardware Interface / ros2_control
- joint_trajectory_controller
- Serial Protocol
- MCU Firmware
- Servo Control
- Physical Motion
04
Technology
- ROS 2
- C++
- ros2_control
- joint_trajectory_controller
- Serial
- MCU Firmware
- URDF / Xacro
- TF
- robot_state_publisher
- /joint_states
- MoveIt 2
- Watchdogs
- Diagnostics
Next project
04 — Autonomous Delivery Robotics