
Physical AI Autonomous Delivery Robot
A 28-week Physical AI creation and engineering project focused on building a physical, language-conditioned autonomous delivery platform.
- ROS 2
- Physical AI
- Manipulation
- Navigation
- Robot Learning
01
What it does
A 28-week Physical AI creation and engineering project focused on building a physical, language-conditioned autonomous delivery platform.
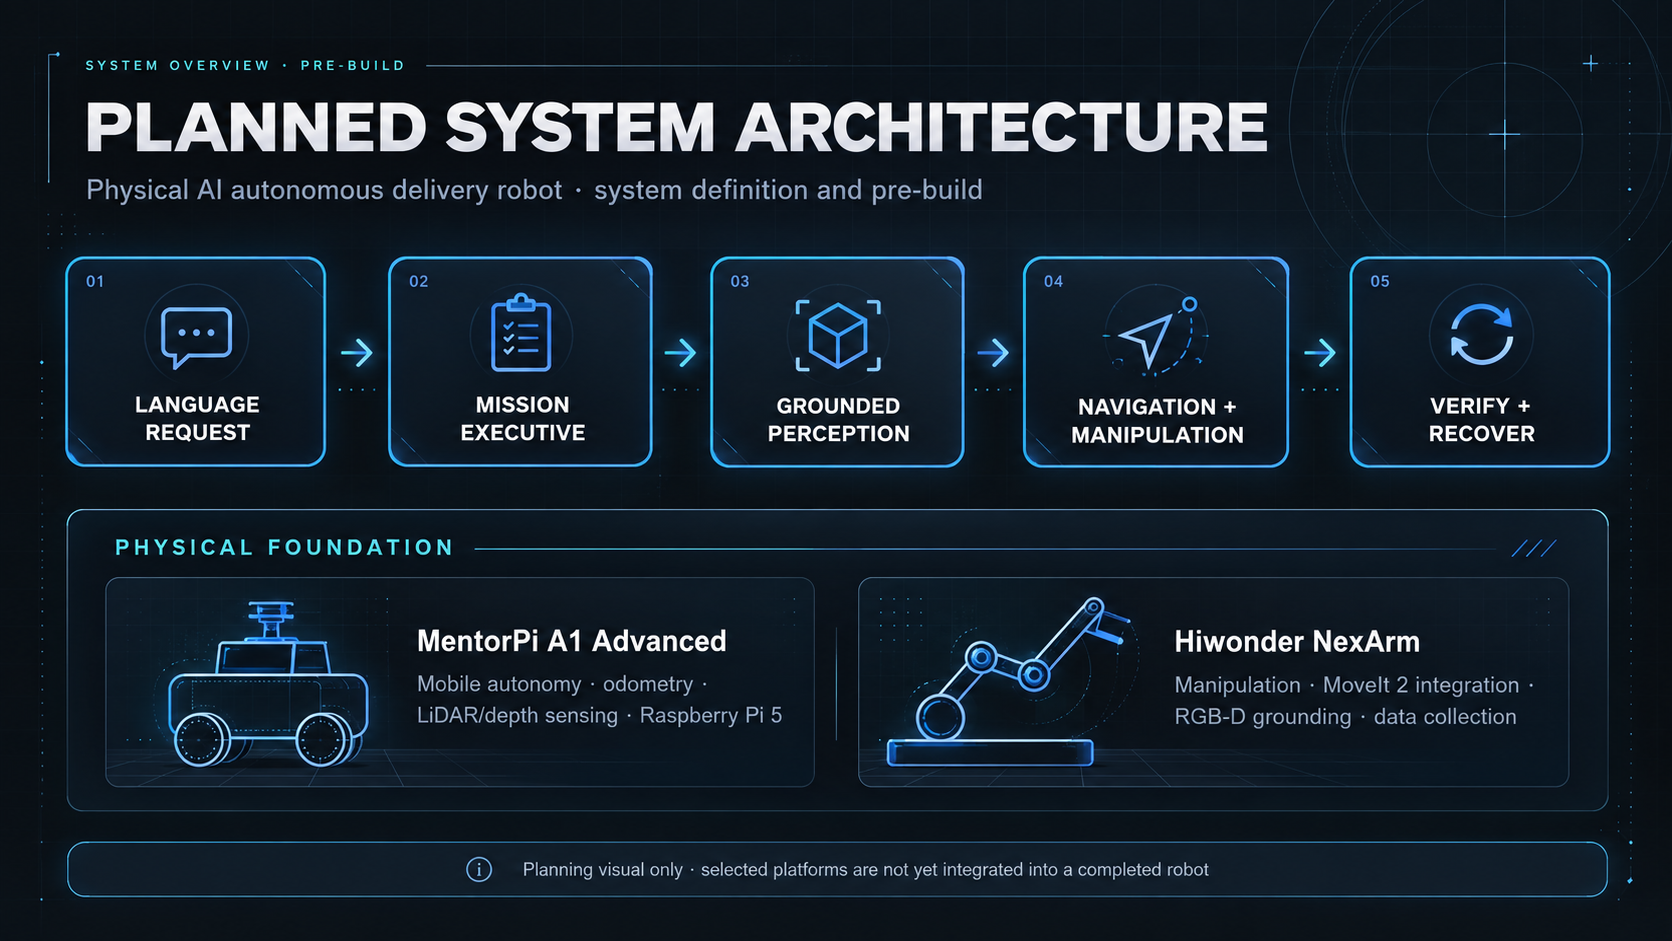
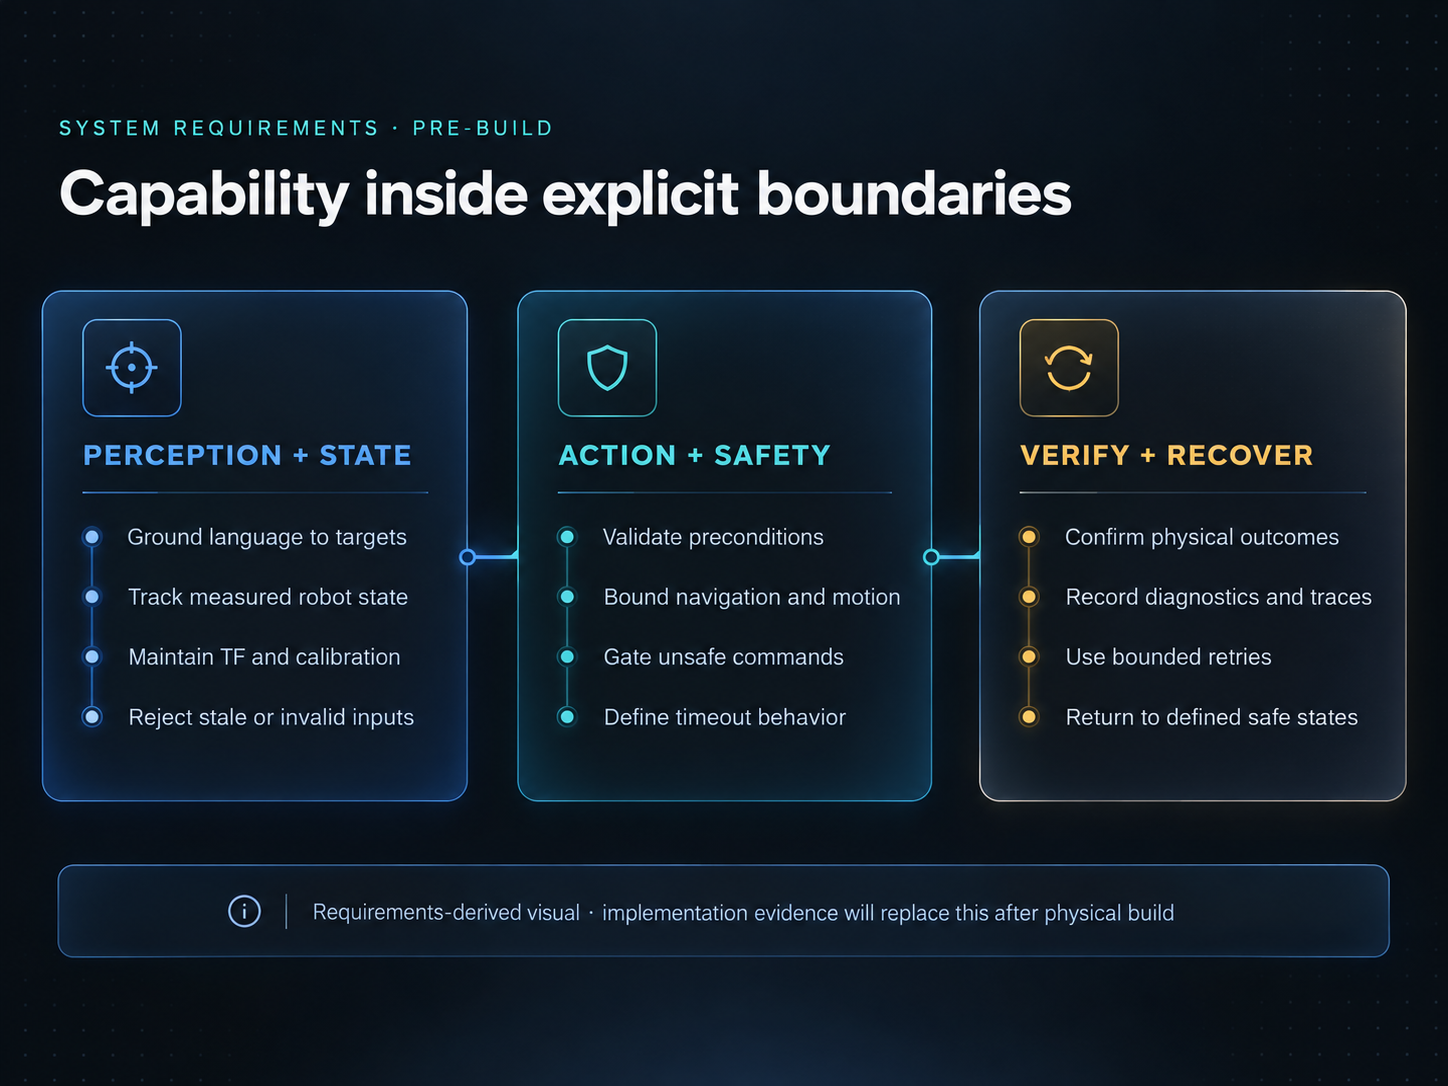
The system is being designed as one cumulative robotics platform combining ROS 2 hardware integration, grounded perception, manipulation, autonomous navigation, robot learning, semantic scene understanding, safety, recovery and reproducible system validation.
Current phase
System architecture, requirements, execution planning and hardware selection are complete. Physical implementation is the next stage.
02
Demonstrations
03
System overview
- 01
System Definition
● Complete
- 02
Physical Foundation
○ Next
- 03
Grounding → Action MVP
- 04
Robot Learning
- 05
Scene Reasoning
- 06
Human-Aware Autonomy
- 07
Integration & Validation
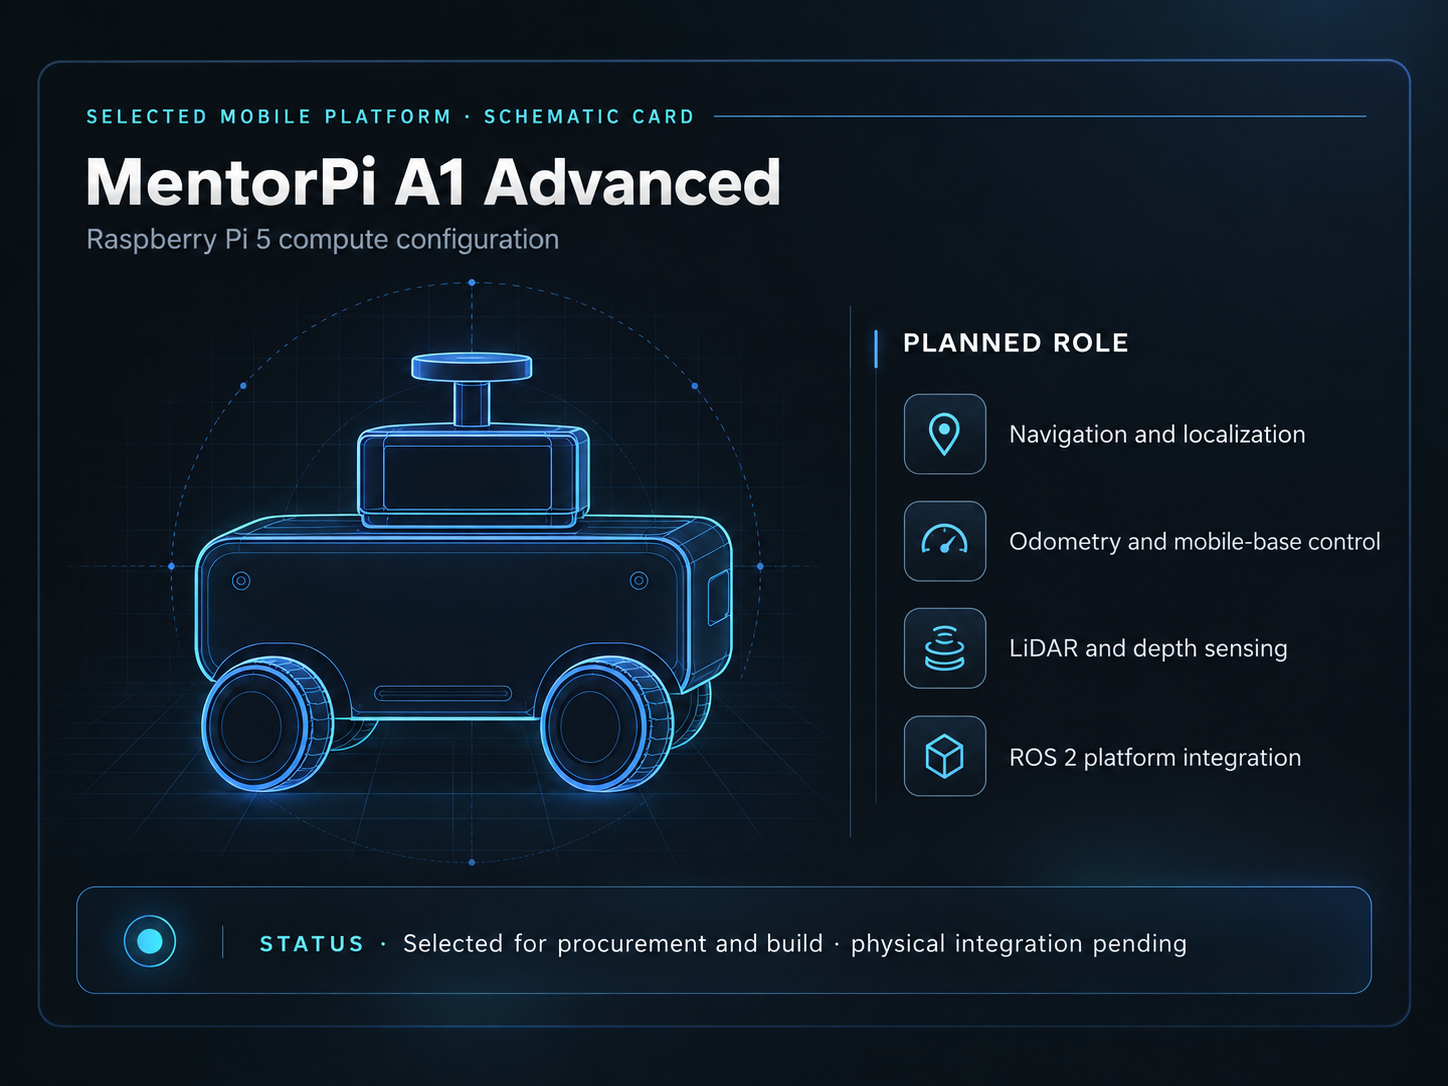
Mobile platform
Hiwonder MentorPi A1 Advanced
Raspberry Pi 5
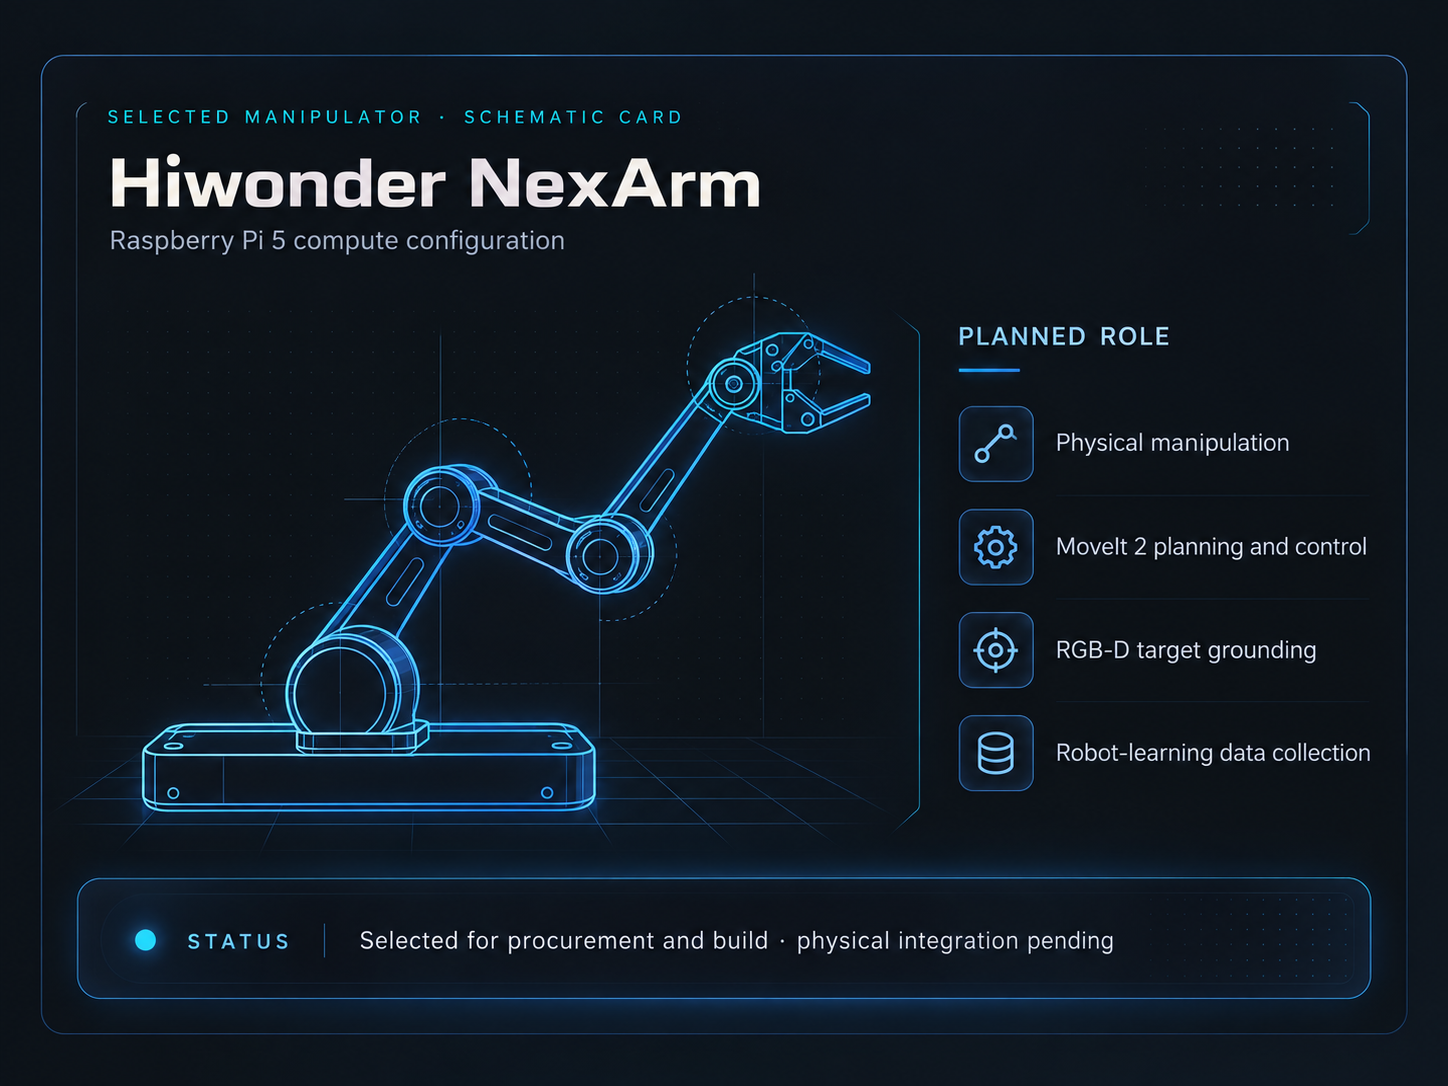
Manipulator
Hiwonder NexArm
Physical bring-up platform
Adeept 5-DOF Robotic Arm
The project builds on earlier work in autonomous delivery robotics, adaptive visual grounding and physical ROS 2 hardware integration.
Next project
02 — Adaptive Visual Grounding for Robot Vision